Modern AI runs on digital information: text, images and video that can be stored and processed at scale. Robots ask for something harder. They act on the world, so they need to know what their actions do to it.
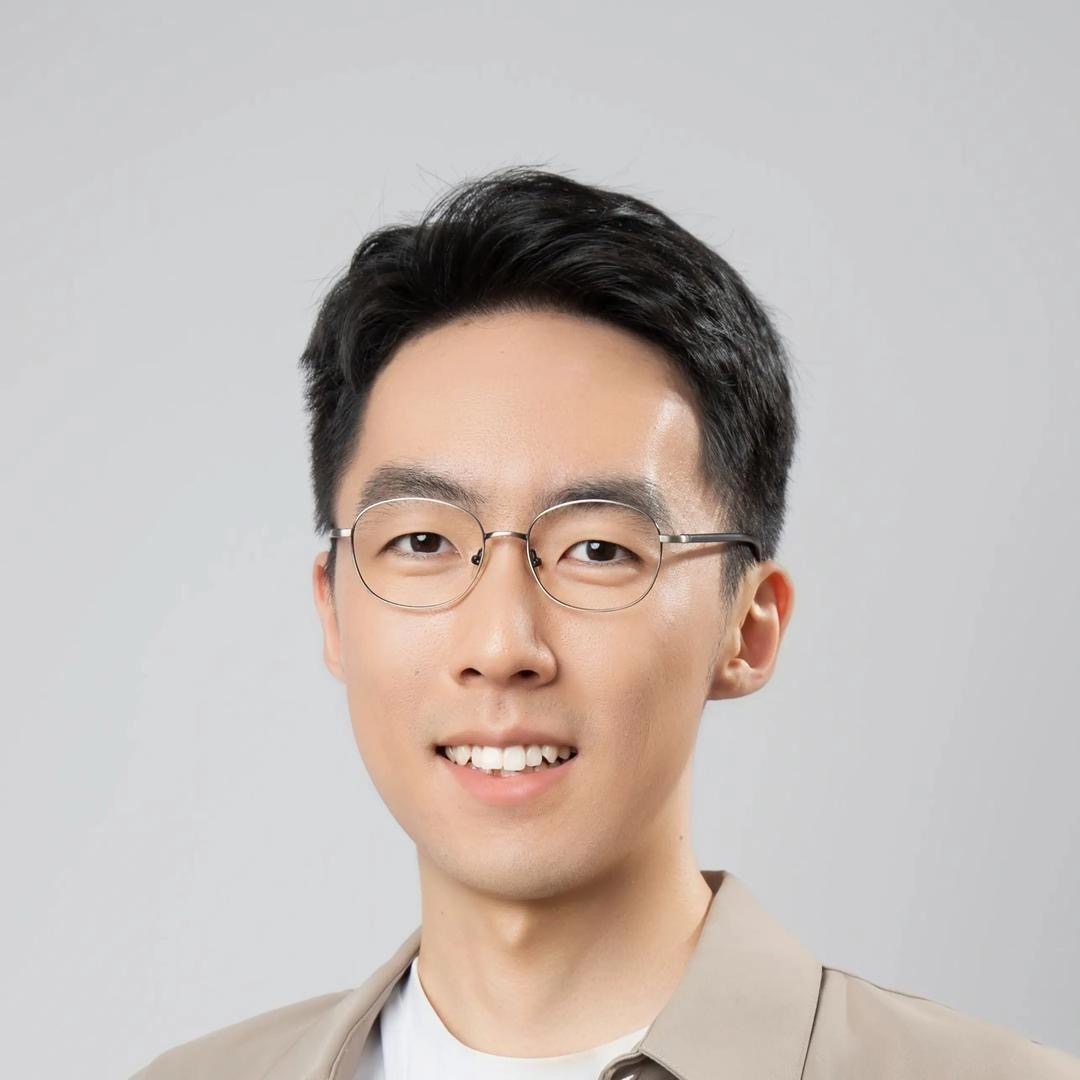
Zhaoxi Chen, Co-Founder and CEO of Ropedia, has built a company around that problem: collecting robotics training data from the real world. In this interview with The BB Report, Chen explains where current data falls short, how Ropedia captures and processes real-world experience, and how the company tests whether its data makes robots more capable.
At a glance
- Who: Zhaoxi Chen, Co-Founder and CEO of Ropedia
- What Ropedia builds: data infrastructure for robotics and embodied AI, from capture hardware to processing, datasets and benchmarks
- Capture platform: HOMIE, a wearable system with four wide-angle cameras, inertial sensing and audio
- Research dataset: Xperience-10M, with 10 million interactions across 10,000 hours of recordings
- Latest research: six projects unveiled during Ropedia Super Week
1. The problem: why today’s AI data falls short for robots
“Today’s AI infrastructure is very good at storing and processing digital information,” Chen says. “But when you add robotics into the picture, there is another requirement: a reliable record of how actions change the physical world.”
A simple example: picking up a cup
To pick up a cup, a robot has to know where it is, how its own body and fingers are moving, and what happens at the moment of contact. Every one of those signals has to line up in time and space. “A video may show the task succeeding but it will leave much of that information unobserved,” Chen says.
The gaps Chen identifies
- Physical grounding: data tied to what actually happens in the physical world
- Synchronized observation and action: what is seen and what is done, aligned in time and space
- Coverage of changing environments: data from settings that do not stay the same
- A link to performance: data quality connected to how a robot actually performs
In Chen’s view, robotics infrastructure has to cover the whole journey, from capturing an interaction to establishing whether learning from it helps a robot succeed somewhere unfamiliar.
2. Capturing experience where it happens
The challenge
Collecting this kind of data at scale is difficult because the measurements have to stay accurate while people and objects move naturally. Add more devices, more operators and more locations, and the differences between them multiply the problem.
Ropedia’s answer: the HOMIE platform
HOMIE pairs wearable capture hardware with processing software.
- What HOMIE Gen2 records: four wide-angle cameras, inertial sensing and audio, with synchronized capture and calibration as the foundation for spatial reconstruction
- What the processing models derive: depth, camera trajectories, hand motion and full-body movement
- What that achieves: a link between what a person sees and how they move and interact
“The wearable format also lets us bring data collection into the environments where activities naturally happen, which is essential for scaling both the amount of experience and its diversity.”
Zhaoxi Chen, Co-Founder and CEO of Ropedia
3. From raw recordings to training data
Ropedia converts each recording into a structured description of an interaction: where the observer moved, how the hands moved, which objects were involved and how the scene changed over time.
The four stages of the pipeline
- Spatial reconstruction
- Motion estimation
- Object tracking
- Language annotation
EgoXperience
Ropedia’s full-stack research framework and dataset. It aligns visual observations with depth, camera poses, hand representations, object trajectories, object geometry and task descriptions. Its object-tracking pipeline checks each proposed trajectory against evidence such as depth, silhouettes and motion consistency.
Holi-World
The company’s integrated research framework and ecosystem. It extends the approach to persistent scene understanding by placing static and moving objects in one shared spatial representation, so any training example can be traced back to particular objects, moments and frames.
One experience, several uses
That structure lets a single recording serve several learning problems, including spatial reasoning, world prediction and learning actions from demonstrations. “Validation is central because errors in reconstructed geometry or motion can become errors in what a model learns,” Chen says.
4. What makes data robotics-ready
“Essentially, robotics-ready data must preserve the relationship between observations, actions and outcomes.”
Zhaoxi Chen, Co-Founder and CEO of Ropedia
More than a caption
A description such as “a person opened a drawer” is useful, Chen says, but a robot learning the task also needs:
- the approach
- the grasp
- the drawer’s movement
- any adjustment along the way
Human demonstrations carry a great deal of that information, although transferring it to a robot still means accounting for the robot’s own body and control system.
Where Ropedia collects
Ropedia records in kitchens, factories, hotels, retail spaces and homes. Within each setting, useful coverage depends on variation in objects, layouts, starting conditions and the way a task is carried out.
Why edge cases matter
“A slipping grasp or an obstructed drawer can reveal a capability gap that thousands of repetitions of an easy interaction would leave unresolved,” Chen says. Evaluation results guide which experiences the company collects next.
5. The data the robotics industry still lacks
Chen points to three gaps.
Gap 1: Long, continuous tasks
Continuous, richly annotated experience that links whole-body movement with detailed manipulation is scarce. Many useful tasks combine walking, reaching, using both hands and adapting to what happens next. Carrying items between rooms or preparing a workspace is an extended sequence, and capturing it with consistent geometry, hand motion, object tracking and task context is difficult.
Gap 2: Contact-rich interactions
Handling clothing or cables, or adjusting when an object slips, depends on physical properties, contact forces among them, that visual recordings alone do not directly measure.
Gap 3: Recovery
A capable robot has to carry on after an imperfect grasp, a displaced object or an interrupted task. “Those moments are particularly valuable because they expose the difference between performing a familiar routine and adapting to the world,” Chen says.
6. How Ropedia measures whether its data helps
Ropedia splits evaluation into three layers.
| Layer | The question it answers | How it is measured |
|---|---|---|
| Measurement quality | Are the representations accurate? | Camera trajectory error, depth error, hand-joint position error, object-tracking consistency and annotation correctness, each against a defined reference; benchmarks include EgoX-Bench and Holi-World-Bench |
| Coverage | Which tasks, objects, environments and difficult conditions does the data represent? | Performance on held-out objects and scenes, which separates generalization from familiarity |
| Learning value | Does the data make a robot better? | Task success, task progress, recovery and the amount of additional robot data needed |
The result that matters most
Chen calls learning value “the ultimate test.” In Ropedia’s experiments with W0, held-out success on the LIBERO-Plus benchmark rose from 50.1% to 56.8%, with the other training settings unchanged.
To prove what any single dataset contributes, a team has to run controlled comparisons of training with and without it. “The objective is to connect every quality claim to a measurable capability,” Chen says.
7. Ropedia’s infrastructure in practice
How the system works
- Field collection: operators wear HOMIE to record assigned activities
- Central management: the capture platform handles task distribution, uploads and review
- Processing: the pipeline turns each recording into aligned spatial, motion and semantic representations
- Dataset delivery: the processed datasets are handed over for training and evaluating physical AI models
Ropedia by the numbers
| Item | Figure |
|---|---|
| Xperience-10M research dataset | 10 million interactions across 10,000 hours of recordings |
| Xperience-10M modalities | Video, audio, depth, camera trajectories, hand and full-body motion, inertial signals and language annotations |
| Xperience Enterprise specification | 100,000 hours across 5,000 scenes and nine scene categories |
| W0 training corpus | 10,000 hours of human experience and 3,000 hours of robot experience |
| W0 result on LIBERO-Plus (held out) | Success rose from 50.1% to 56.8% |
W0’s corpus draws on public sources and Ropedia’s own recordings, placed in a common representation. It shows the infrastructure supporting learning across human and robot bodies, alongside benchmarks that test both prediction and downstream usefulness.
8. Ropedia Super Week: six research projects
During Ropedia Super Week, the company unveiled six research projects:
- EgoXperience
- Holi-World
- S-Agent 2.0
- Ropedia W0
- DONIC
- Ropedia-A0
In practice: a robot that tidies a room
Chen ties the research to an everyday scene. A household robot tidying a room has to find an object, work out whether someone has moved it, approach it, pick it up and put it where it belongs.
| What the robot needs | Project | How it helps |
|---|---|---|
| Know the room and the objects in it | EgoXperience | Reconstructs the spatial relationship between cameras, hands, objects and the surrounding scene |
| Notice when things move | Holi-World | Tracks where objects are and how they move over time, so a robot can keep up with a changing room |
| Choose an action before acting | Ropedia W0 | Predicts future first-person views based on movement and manipulation; Ropedia has explored using it to evaluate and select candidate actions before execution |
| Use both hands together | DONIC | Learns coordinated two-handed manipulation by tracking human demonstrations, with generalization to unseen movements and objects evaluated in simulation; relevant to holding a container steady while handling what is inside it |
“The practical opportunity is to help robots learn from human experience, reason about changing surroundings and practice more effectively before acting in the physical world.”
Zhaoxi Chen, Co-Founder and CEO of Ropedia
9. The road ahead
“We need to make useful physical experience inexpensive to capture, reliable to process and straightforward to evaluate,” Chen says.
Where the data will come from
- Human activity: people already perform a wide range of tasks at home and at work, and wearable collection can capture that experience
- Robot demonstrations and deployment feedback: the information specific to a robot’s body
- Simulation and world models: a way to expand training and testing
What makes an hour of data worth having
For Chen, the measure is how much reliable learning signal each hour contains. Quality, multimodal density and diversity decide how much additional data adds to a robot’s capability.
Ropedia’s long-term direction
Ropedia plans to connect data services, capture and processing infrastructure, model services and benchmarks into one cycle. Better models pull more value out of recordings, better data improves the models, and evaluation shows which gaps to tackle next.
“And making that cycle faster can reduce the amount of infrastructure every robotics team has to build independently.”
Zhaoxi Chen, Co-Founder and CEO of Ropedia
Learn more
Readers can learn more about Ropedia and its physical AI data infrastructure at https://ropedia.com.